1 556 kr
Skickas inom 11-20 vardagar
1 556 kr
Skickas inom 11-20 vardagar
2 109 kr
Läs direkt efter köp
1 473 kr
Skickas inom 11-20 vardagar
2 094 kr
Läs direkt efter köp
3 758 kr
Läs direkt efter köp
2 619 kr
Skickas inom 11-20 vardagar
1 923 kr
Skickas inom 11-20 vardagar
2 450 kr
Läs direkt efter köp
2 573 kr
Skickas inom 10-15 vardagar
3 276 kr
Läs direkt efter köp
This book describes the substantial progress recently made in the development of micro and nanorobotic systems, utilizing magnetic, optical, acoustic, electrical, and other actuation fields. It covers several areas of micro and nanorobotics including robotics, materials science, and biomedical engineering. Field-Driven Micro and Nanorobots for Biology and Medicine provides readers with fundamental physics at the micro and nano scales, state-of-the-art technical advances in field-driven micro and nanorobots, and applications in biological and biomedical disciplines.
2 573 kr
Skickas inom 10-15 vardagar
1 569 kr
Skickas inom 10-15 vardagar
1 962 kr
Läs direkt efter köp
1 569 kr
Skickas inom 10-15 vardagar
1 090 kr
Skickas inom 10-15 vardagar
1 459 kr
Läs direkt efter köp
1 082 kr
Skickas inom 10-15 vardagar
First Robotic Grasping and Manipulation Challenge, RGMC 2016, Held in Conjunction with IROS 2016, Daejeon, South Korea, October 10–12, 2016, Revised Papers
567 kr
Skickas inom 10-15 vardagar
739 kr
Läs direkt efter köp
2 428 kr
Läs direkt efter köp
2 428 kr
Läs direkt efter köp
551 kr
Skickas inom 10-15 vardagar
718 kr
Läs direkt efter köp
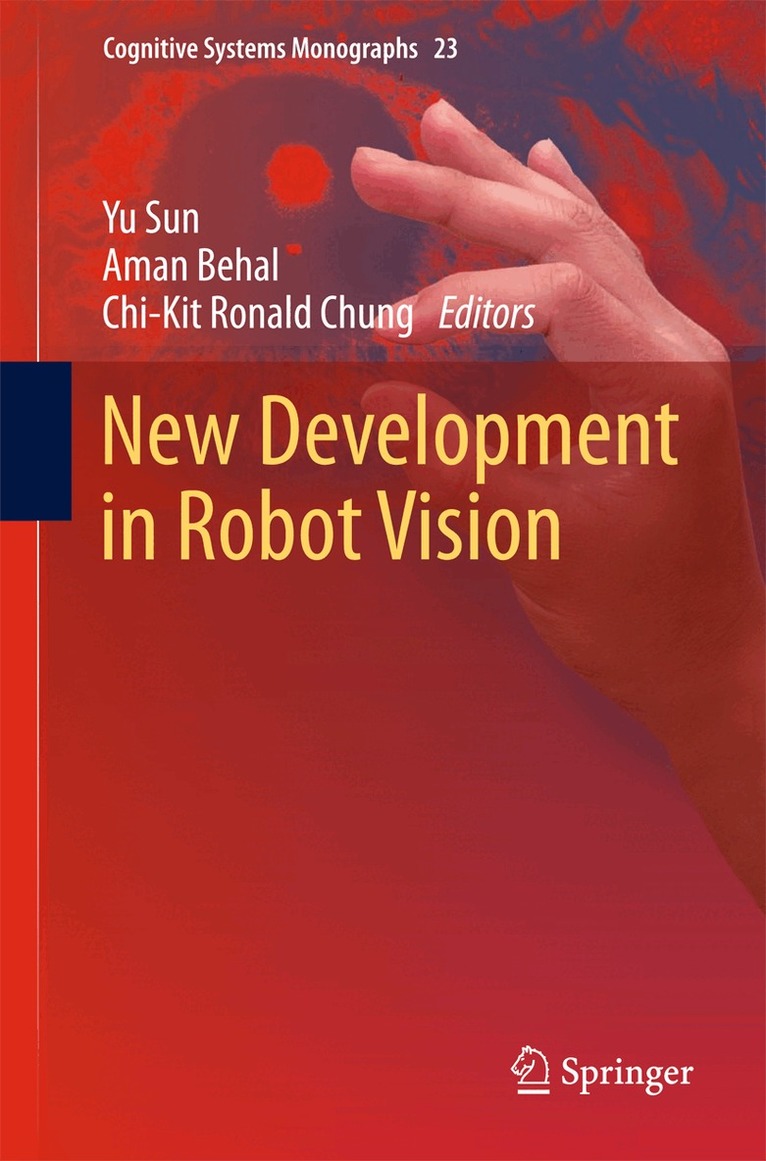
The field of robotic vision has advanced dramatically recently with the development of new range sensors. Tremendous progress has been made resulting in significant impact on areas such as robotic navigation, scene/environment understanding, and visual learning. This edited book provides a solid and diversified reference source for some of the most recent important advancements in the field of robotic vision. The book starts with articles that describe new techniques to understand scenes from 2D/3D data such as estimation of planar structures, recognition of multiple objects in the scene using different kinds of features as well as their spatial and semantic relationships, generation of 3D object models, approach to recognize partially occluded objects, etc. Novel techniques are introduced to improve 3D perception accuracy with other sensors such as a gyroscope, positioning accuracy with a visual servoing based alignment strategy for microassembly, and increasing object recognition reliability using related manipulation motion models. For autonomous robot navigation, different vision-based localization and tracking strategies and algorithms are discussed. New approaches using probabilistic analysis for robot navigation, online learning of vision-based robot control, and 3D motion estimation via intensity differences from a monocular camera are described. This collection will be beneficial to graduate students, researchers, and professionals working in the area of robotic vision.
551 kr
Skickas inom 10-15 vardagar
514 kr
Skickas inom 7-10 vardagar
525 kr
Skickas inom 7-10 vardagar
509 kr
Skickas inom 7-10 vardagar
514 kr
Skickas inom 7-10 vardagar
509 kr
Skickas inom 7-10 vardagar
1 463 kr
Skickas inom 10-15 vardagar