962 kr
Läs direkt efter köp
962 kr
Läs direkt efter köp
1 990 kr
Läs direkt efter köp
This book describes two modern technologies for capturing high-accuracy panoramic images and range data, namely the use of sensor-line cameras and laser range-finders. It provides mathematically accurate descriptions of the geometry of these sensing technologies and the necessary information required to apply them to 3D scene visualization or 3D representation. The book is divided into three parts:
Part One contains a full introduction to panoramic cameras and laser range-finders, including a discussion of calibration to aid preparation of equipment ready for use. Part Two explains the concept of stereo panoramic imaging, looking at epipolar geometry, spatial sampling, image quality control and camera analysis and design. Part Three looks at surface modelling and rendering based on panoramic input data, starting with the basics and taking the reader through to more advanced techniques such as the optimization of surface meshes and data fusion. There is also an accompanying website containing high-resolution visual samples and animations, illustrating techniques discussed in the text.Panoramic Imaging is primarily aimed at researchers and students in engineering or computer science involved in using imaging technologies for 3D visualization or 3D scene reconstruction. It is also of significant use as an advanced manual to practising engineers in panoramic imaging. In brief, the book is of value to all those interested in current developments in multimedia imaging technology
1 126 kr
Skickas inom 10-15 vardagar
549 kr
Skickas inom 10-15 vardagar
734 kr
Läs direkt efter köp
Computer vision and image analysis require interdisciplinary collaboration between mathematics and engineering. This book addresses the area of high-accuracy measurements of length, curvature, motion parameters and other geometrical quantities from acquired image data. It is a common problem that these measurements are incomplete or noisy, such that considerable efforts are necessary to regularise the data, to fill in missing information, and to judge the accuracy and reliability of these results. This monograph brings together contributions from researchers in computer vision, engineering and mathematics who are working in this area.
The book can be read both by specialists and graduate students in computer science, electrical engineering or mathematics who take an interest in data evaluations by approximation or interpolation, in particular data obtained in an image analysis context.
1 123 kr
Skickas inom 10-15 vardagar
1 502 kr
Läs direkt efter köp
565 kr
Skickas inom 10-15 vardagar
755 kr
Läs direkt efter köp
1 740 kr
Skickas inom 10-15 vardagar
2 201 kr
Läs direkt efter köp
1 740 kr
Skickas inom 10-15 vardagar
505 kr
Skickas inom 10-15 vardagar
688 kr
Läs direkt efter köp
797 kr
Skickas inom 11-20 vardagar
2 073 kr
Skickas inom 7-10 vardagar
1 814 kr
Läs direkt efter köp
2 073 kr
Skickas inom 7-10 vardagar
1 814 kr
Läs direkt efter köp
567 kr
Skickas inom 10-15 vardagar
567 kr
Skickas inom 10-15 vardagar
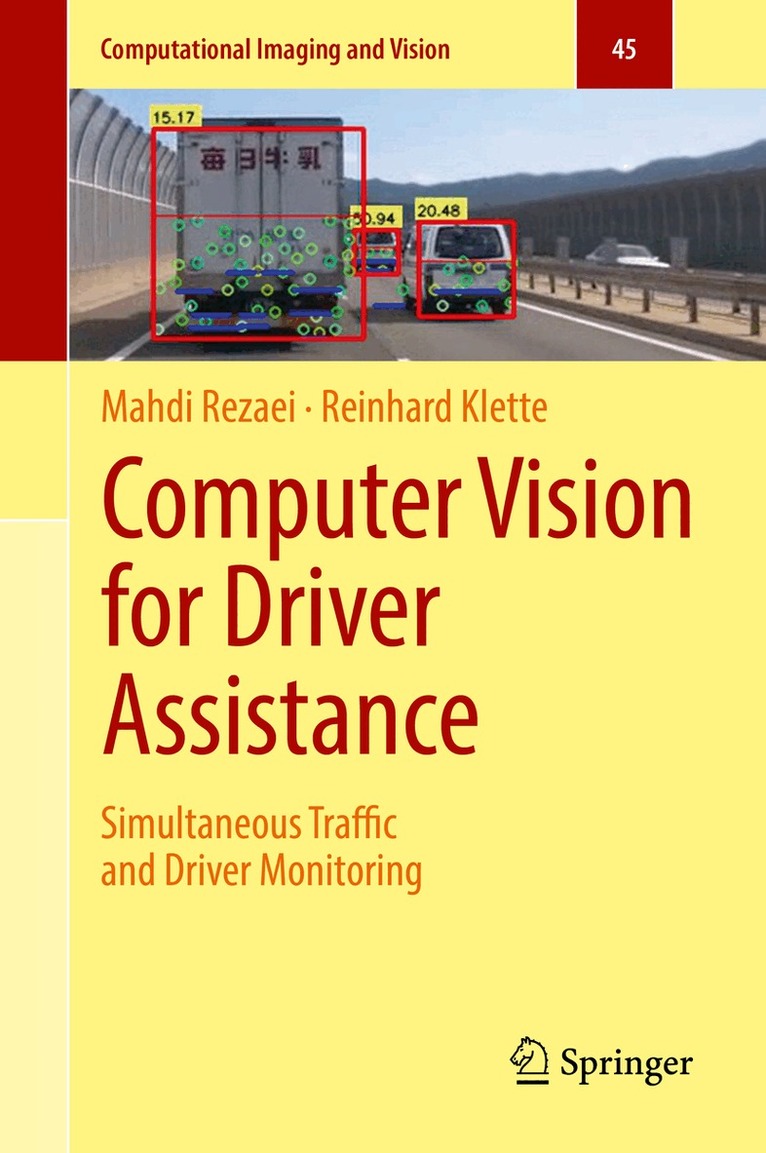
Simultaneous Traffic and Driver Monitoring
1 405 kr
Skickas inom 10-15 vardagar
1 838 kr
Läs direkt efter köp
This book summarises the state of the art in computer vision-based driver and road monitoring, focussing on monocular vision technology in particular, with the aim to address challenges of driver assistance and autonomous driving systems.
While the systems designed for the assistance of drivers of on-road vehicles are currently converging to the design of autonomous vehicles, the research presented here focuses on scenarios where a driver is still assumed to pay attention to the traffic while operating a partially automated vehicle. Proposing various computer vision algorithms, techniques and methodologies, the authors also provide a general review of computer vision technologies that are relevant for driver assistance and fully autonomous vehicles.
Computer Vision for Driver Assistance is the first book of its kind and will appeal to undergraduate and graduate students, researchers, engineers and those generally interested in computer vision-related topics inmodern vehicle design.
4th International Conference, IOV 2017, Kanazawa, Japan, November 22-25, 2017, Proceedings
561 kr
Skickas inom 10-15 vardagar
732 kr
Läs direkt efter köp
Simultaneous Traffic and Driver Monitoring
1 462 kr
Skickas inom 10-15 vardagar
571 kr
Läs direkt efter köp
509 kr
Skickas inom 10-15 vardagar
565 kr
Skickas inom 10-15 vardagar
1 093 kr
Skickas inom 10-15 vardagar